• Aerial robotics applications
  • Ground robotics applications
  • Data-driven adaptive control

Research

My research bridges rigorous control theory and experimental robotics. Theoretical contributions are motivated by limitations that arise in complex autonomous systems, and applications serve as a proving ground for new methods in adaptive, robust, optimal, and data-driven control.
Theoretical Contributions

Data-driven and machine learning adaptive control visualization

Data-driven and Machine Learning Adaptive Control

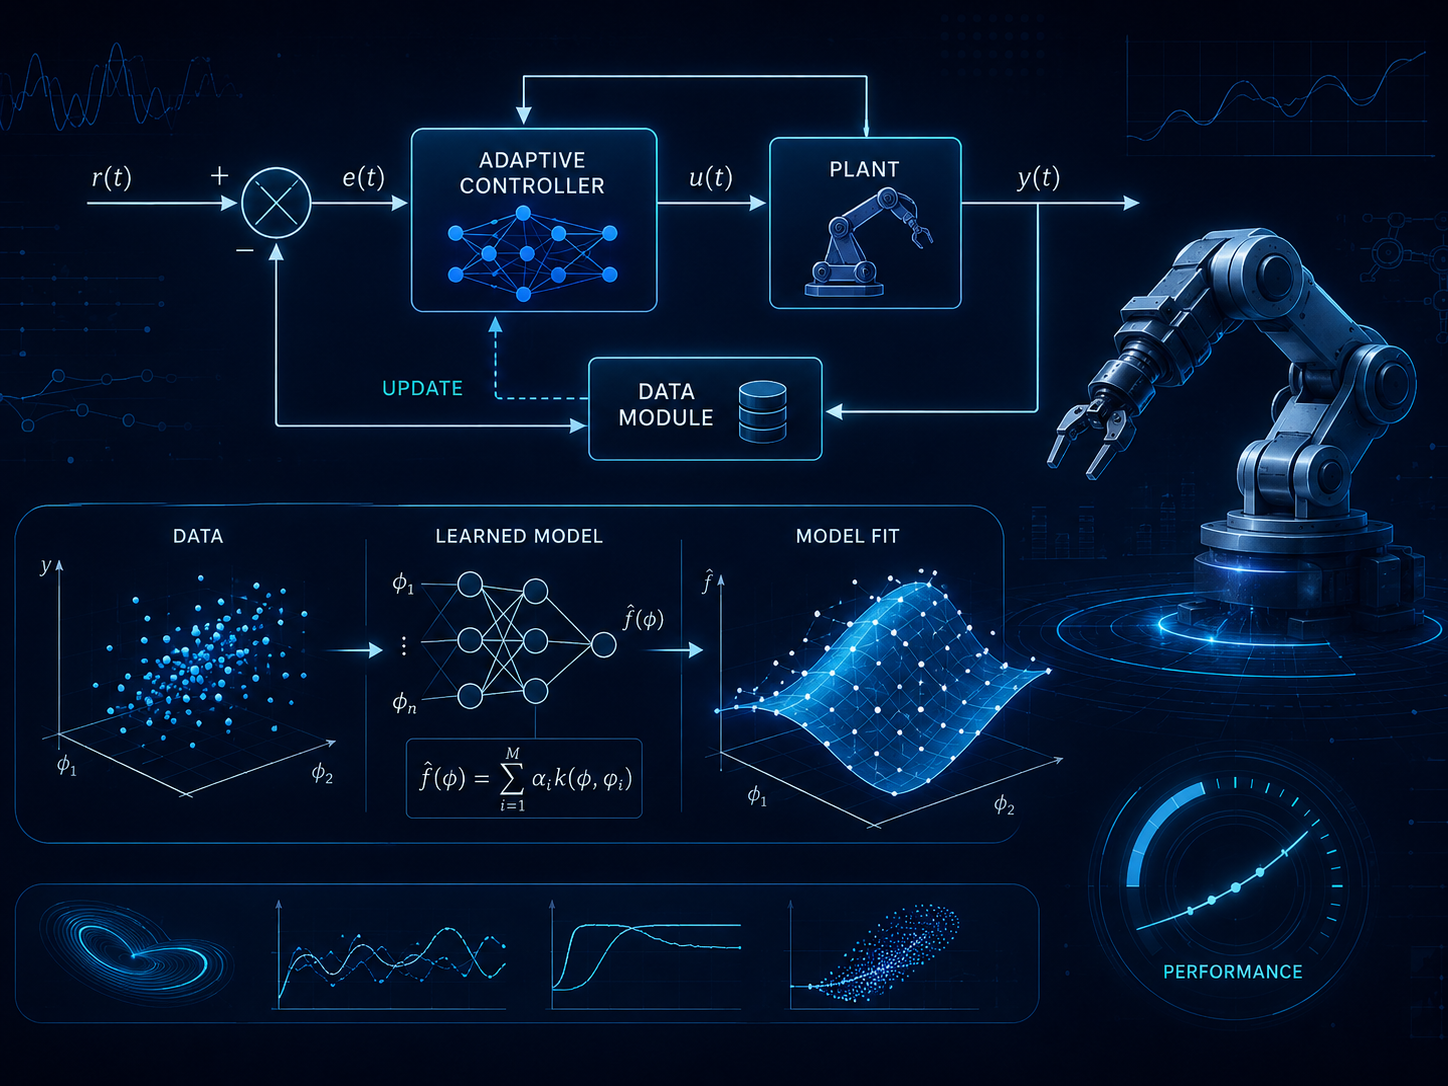
This line of work develops adaptive control methods that learn uncertainty models from data, including reproducing-kernel Hilbert space methods, native-space embeddings, Koopman-operator tools, and data-informed basis selection.

Selected papers

Adaptive control of hybrid dynamical systems visualization

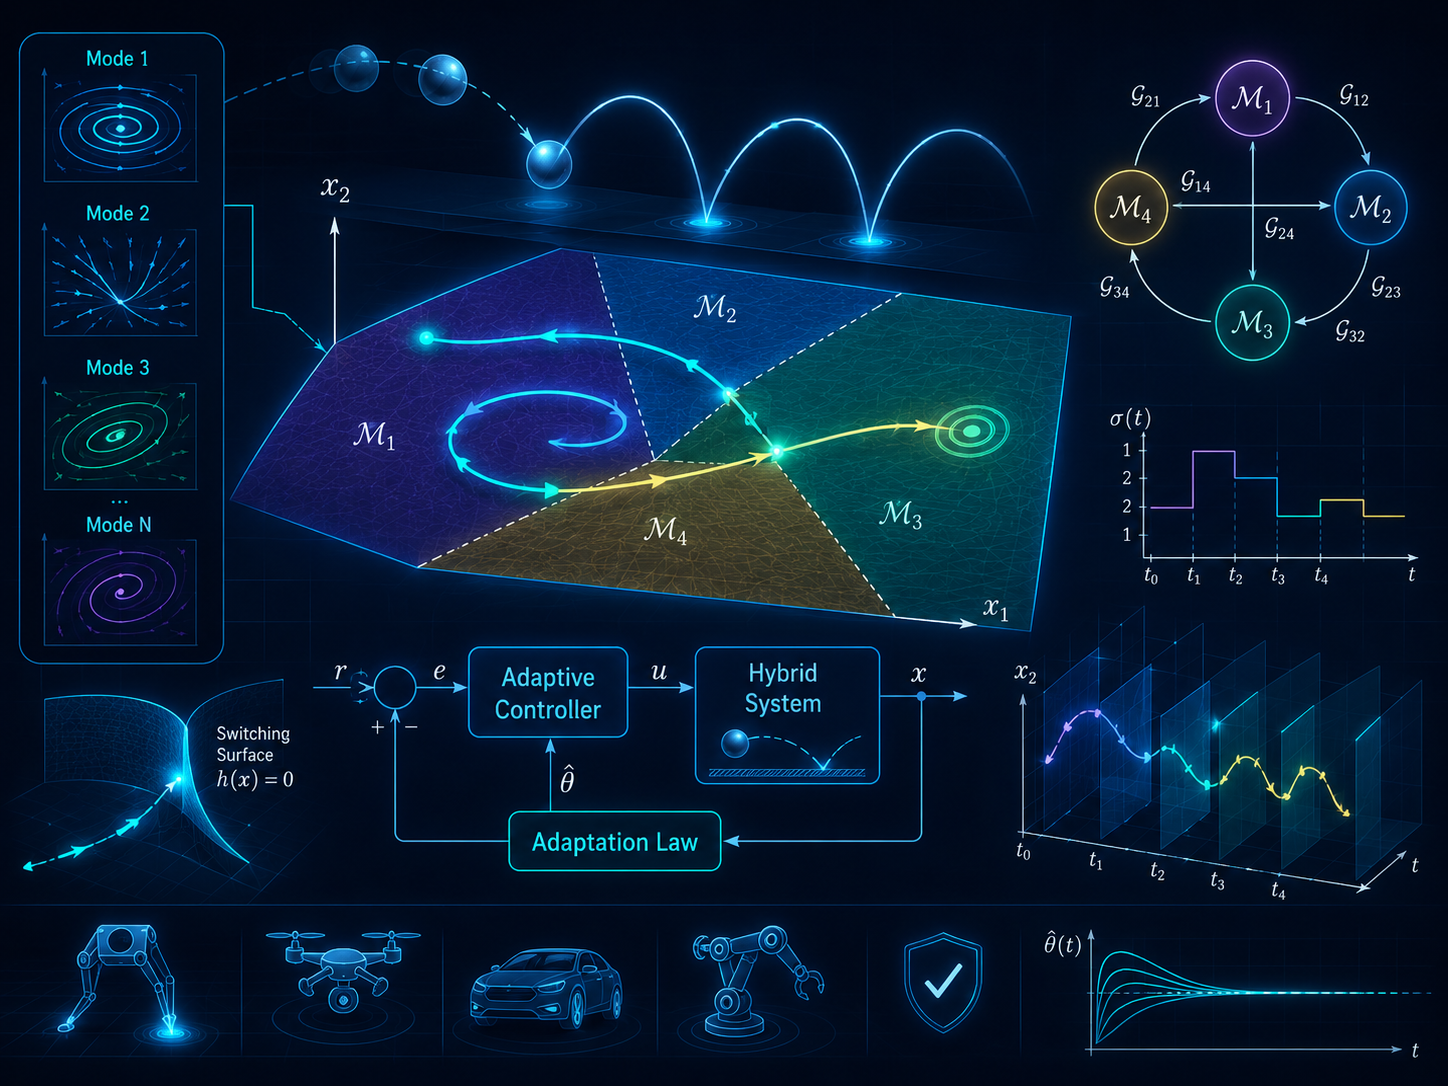
Adaptive Control of Hybrid Dynamical Systems

This research addresses systems whose dynamics switch across modes or include impacts, constraints, and other hybrid phenomena. The goal is to achieve reliable adaptive performance despite time-varying uncertainties and nonsmooth behavior.

Selected papers

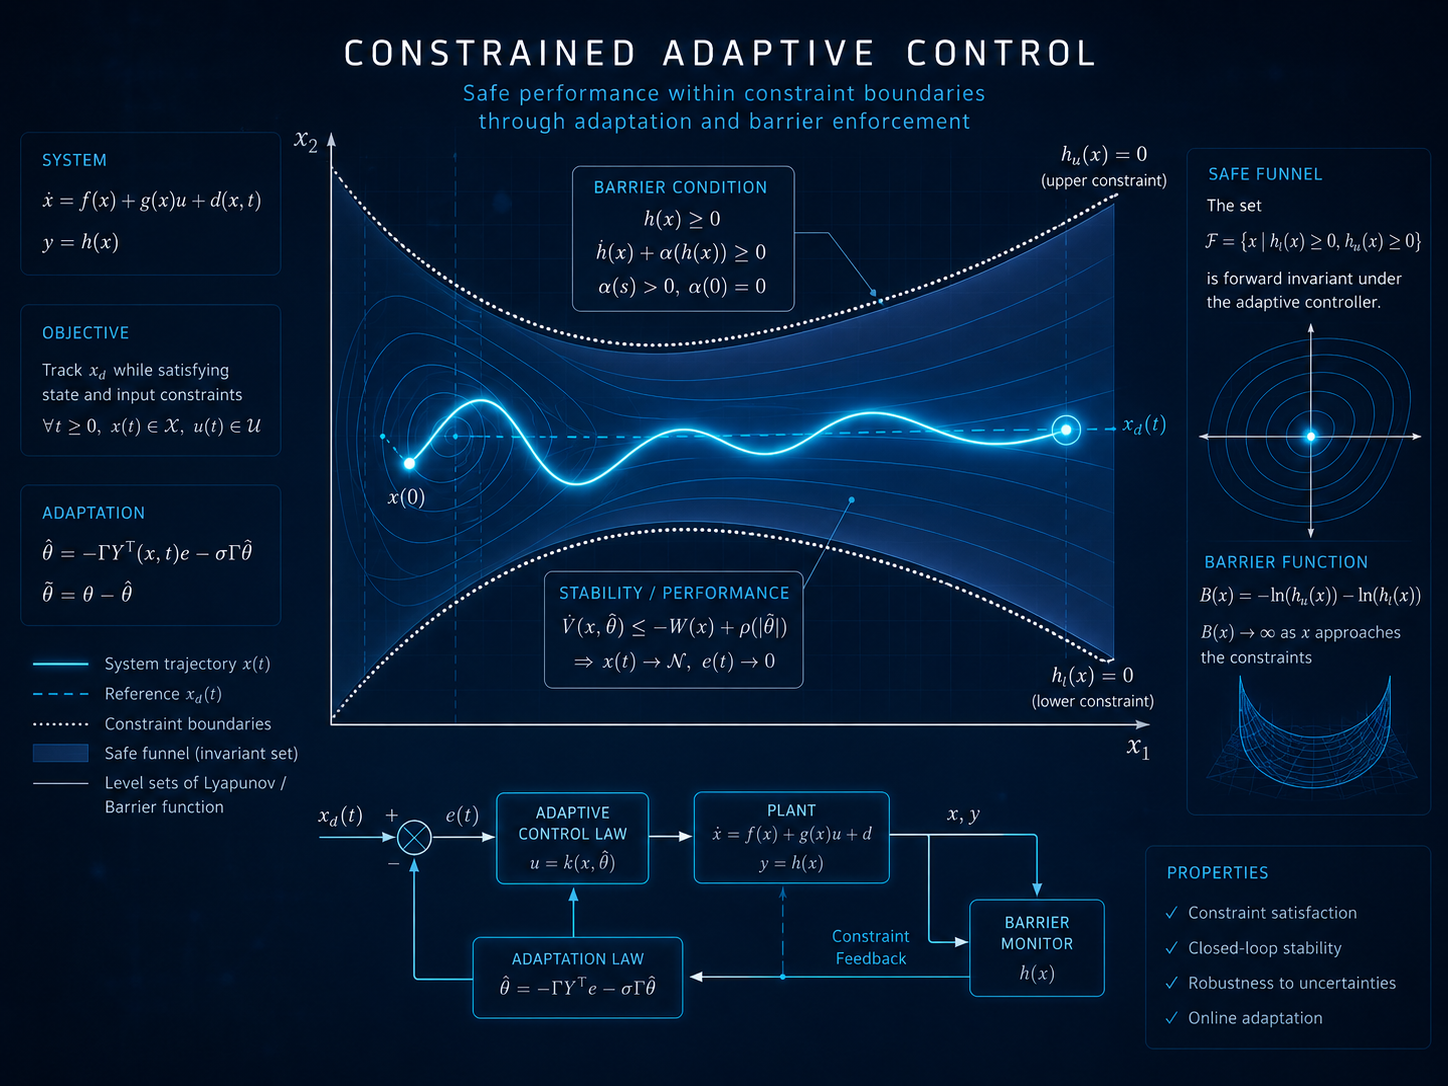
Constrained adaptive control visualization

Constrained Adaptive Control

This topic focuses on adaptive control systems that enforce state, input, tracking-error, transient-performance, and user-defined safety constraints while retaining robustness to uncertainty.

Selected papers

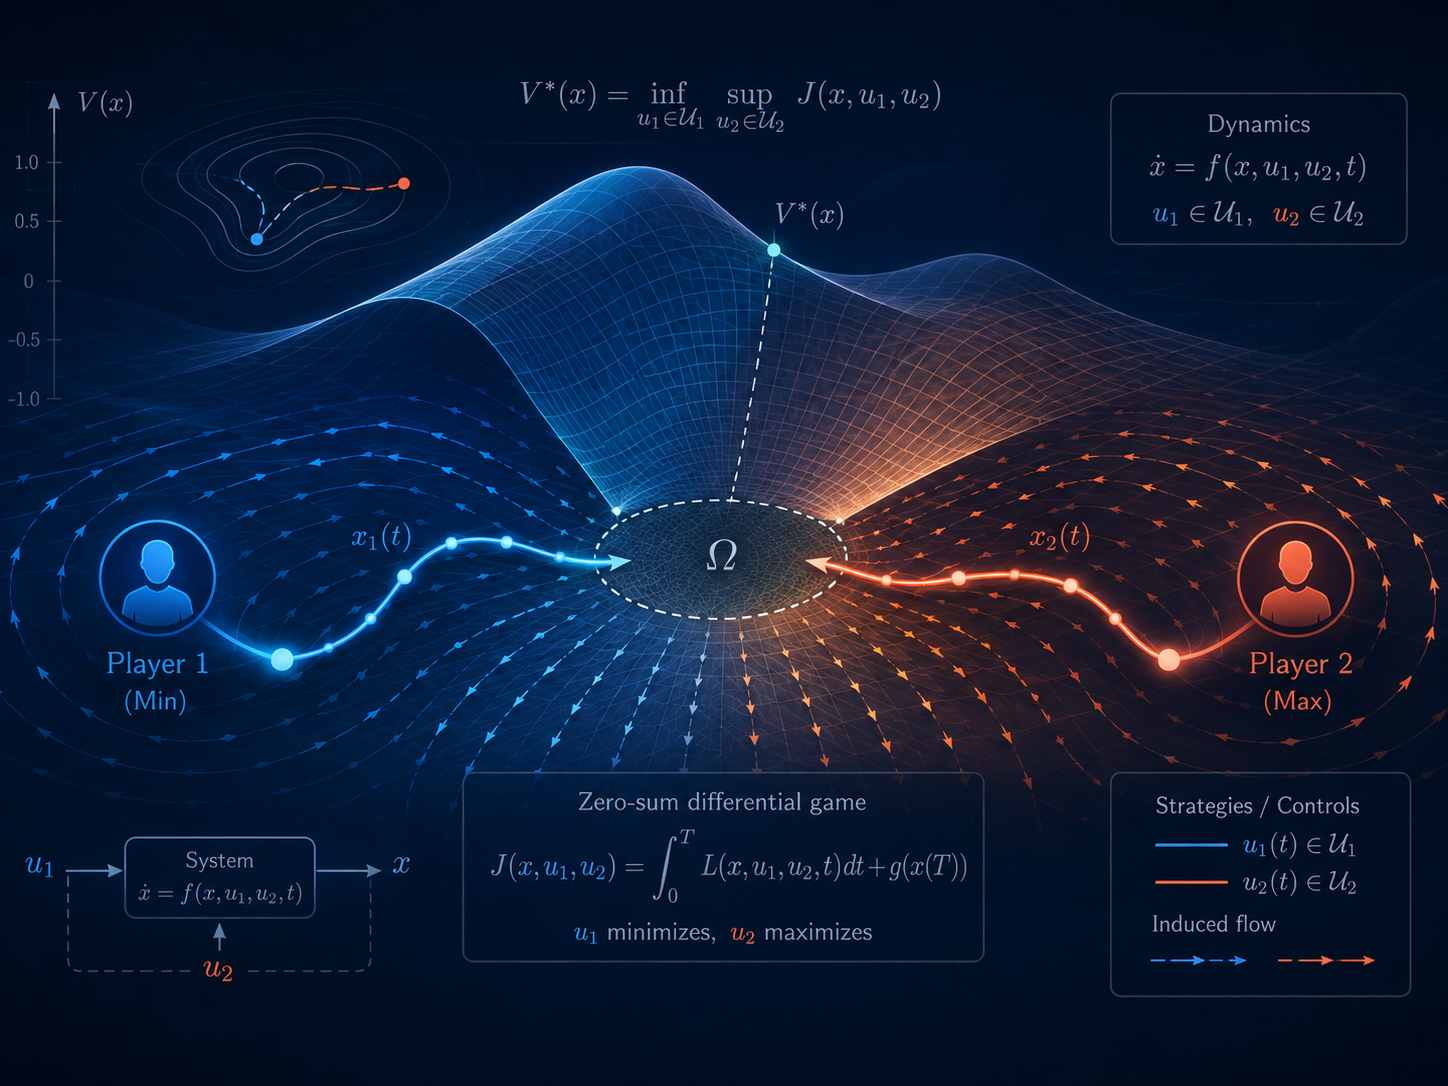
Differential game theory visualization

Optimal Control, Differential Games, and Reinforcement Learning

This research develops optimal and game-theoretic control methods for nonlinear systems, including finite-time stabilization, semistabilization, singular control, policy iteration, and critic/value-function approximation.

Selected papers

Applications

Aerial robotics experiment

Aerial Robotics

Aerial robotics applications include autopilot design, guidance and navigation, tactical mapping, tailsitter and tilt-rotor control, payload transport, shipboard landing, and open-source flight-stack development.

Selected papers

Autonomous ground robot

Ground Robotics

Ground robotics applications focus on terrain-aware autonomy, perception, terramechanics, off-road mobility, and robust control for autonomous ground vehicles operating in uncertain environments.

Selected papers

  • H. White, C. Sandu, J. Mukherjee, A. L'Afflitto, D. Gorsich, and M. Cole. Tire Sinkage Measurement and Entry Angle Calculation Using Stereo Cameras, Journal of Terramechanics, 2025.
  • J. Mukherjee, G. M. Kumar, A. L'Afflitto, H. White, and C. Sandu. Real-Time Ground Segmentation and Terrain Topography Mapping Using Point Clouds, International Society for Terrain-Vehicle Systems Conference, 2025.
  • J. Mukherjee, G. M. Kumar, A. L'Afflitto, H. White, and C. Sandu. Terrain Topology-Informed Motion Planning for Tactical UGVs, CoDIT, 2024.
  • H. White, C. Sandu, J. Mukherjee, A. L'Afflitto, D. Gorsich, and M. Cole. Real-Time Measurement of Tire Sinkage Using Stereo Cameras, International Society for Terrain-Vehicle Systems Conference, 2023.